

Thứ năm, 17/09/2026 | 09:42


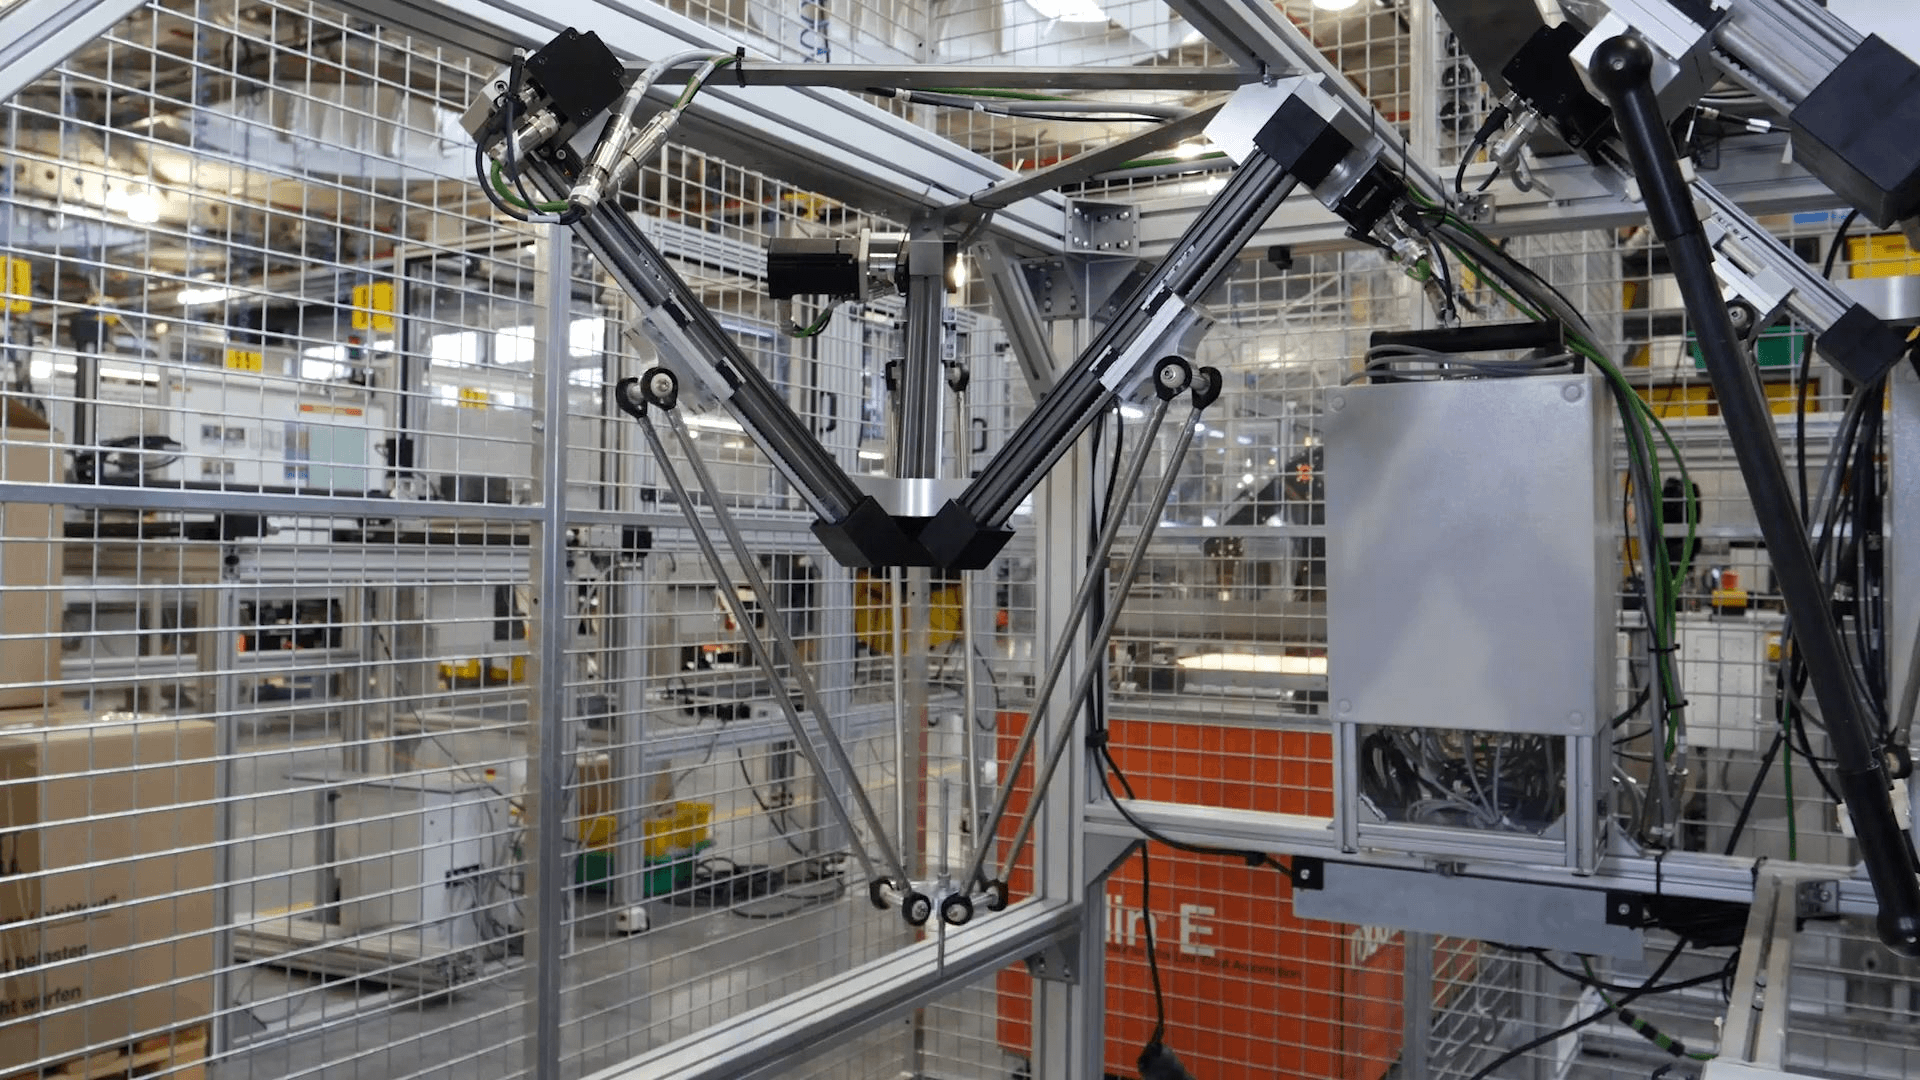
DESIGN OF THE ROBOT DELTA PARAMETER BASED ON THE ROBOT WORKSPACE Abstract: Delta robot is a parallel robot which can provide precise positions of the working head so it is widely used in industrial applications to pick-and-drop products in the production lines. The optimization of parameters of the robot to obtain the desired workspace is an important task. This paper provides a method to determine the robot parameters based on a given robot workspace. The algorithm used to calculate the forward kinematics and the constraints between the basic dimensions of the robot arms are proposed. The optimal algorithm used to limit the parameter domain to the dimensions of the arms of the robot is also proposed in the paper. Keywords: Robot kinematics, Delta robots, robot workspace, simulation |
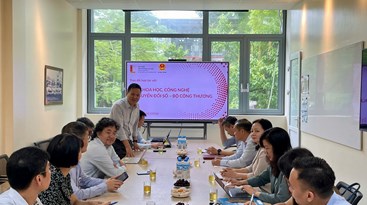
Sáng 16/9, tại Hà Nội, Cục Khoa học, Công nghệ và Chuyển đổi số, Bộ Công Thương có buổi làm việc với Đại học Bách khoa Hà Nội nhằm trao đổi về tiềm năng, định hướng hợp tác trong nghiên cứu khoa học, phát triển công nghệ, đổi mới sáng tạo và chuyển đổi số, gắn với yêu cầu phát triển các lĩnh vực công nghiệp, công nghệ chiến lược của ngành Công Thương.
16/09/2026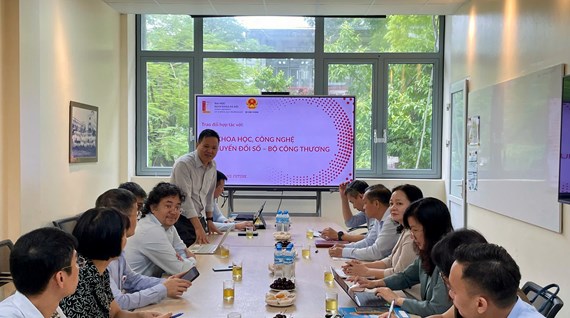
Sáng 16/9, tại Hà Nội, Cục Khoa học, Công nghệ và Chuyển đổi số, Bộ Công Thương có buổi làm việc với Đại học Bách khoa Hà Nội nhằm trao đổi về tiềm năng, định hướng hợp tác trong nghiên cứu khoa học, phát triển công nghệ, đổi mới sáng tạo và chuyển đổi số, gắn với yêu cầu phát triển các lĩnh vực công nghiệp, công nghệ chiến lược của ngành Công Thương.
16/09/2026